|
I am a Ph.D. student in the CMU Robotics Institute, working with Prof. Shubham Tulsiani and Prof. Katerina Fragkiadaki. I'm also a research intern at NVIDIA DAIR. I received my Bachelor's degree in Computer Science from Peking University. During my undergrad years, I have been fortunate to work with Prof. Yue Wang, Prof. Marco Pavone, Prof. Meng Jiang, and Prof. He Wang. I study Robotics, Reinforcement Learning, and 3D/4D Vision. I work on general-purpose dexterous manipulation, from a real-to-sim-to-real and agentic perspective. My research objective is to endow Embodied AI Agents working in complex, unstructured real-world scenes with generalizability, dexterity, and adaptability. How to pronounce my first name?
To approximate: replace the letter "x" with "sh". I also go by Gavin.
Email / GitHub / Google Scholar / Twitter |
Click for domain randomization
|
|
*: Equal Contributions; †: Equal Advising; ‡: Project Lead |
|
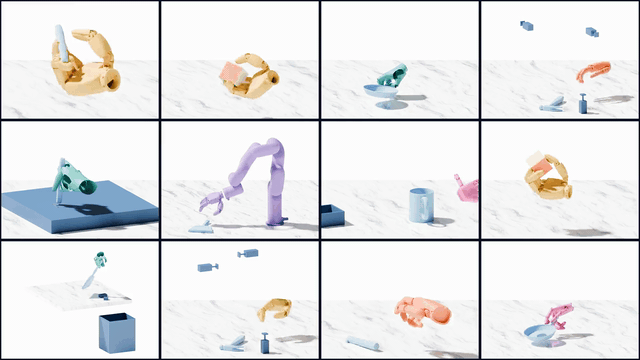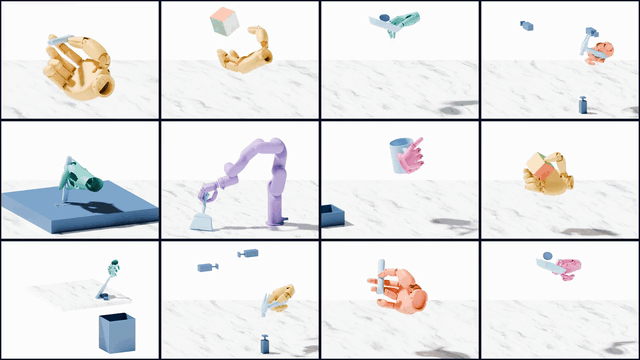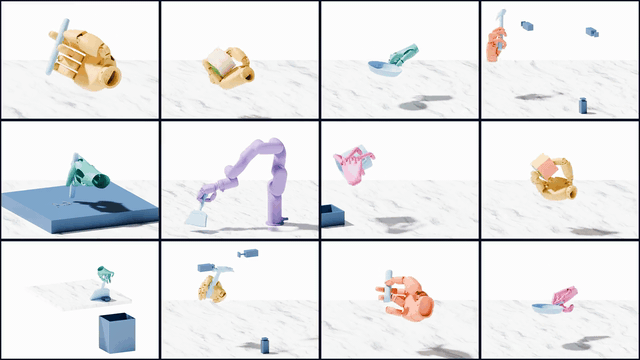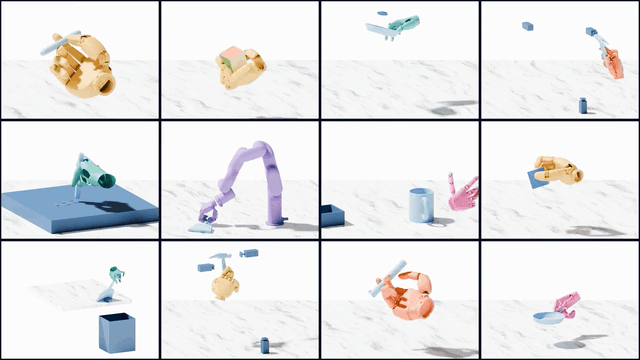
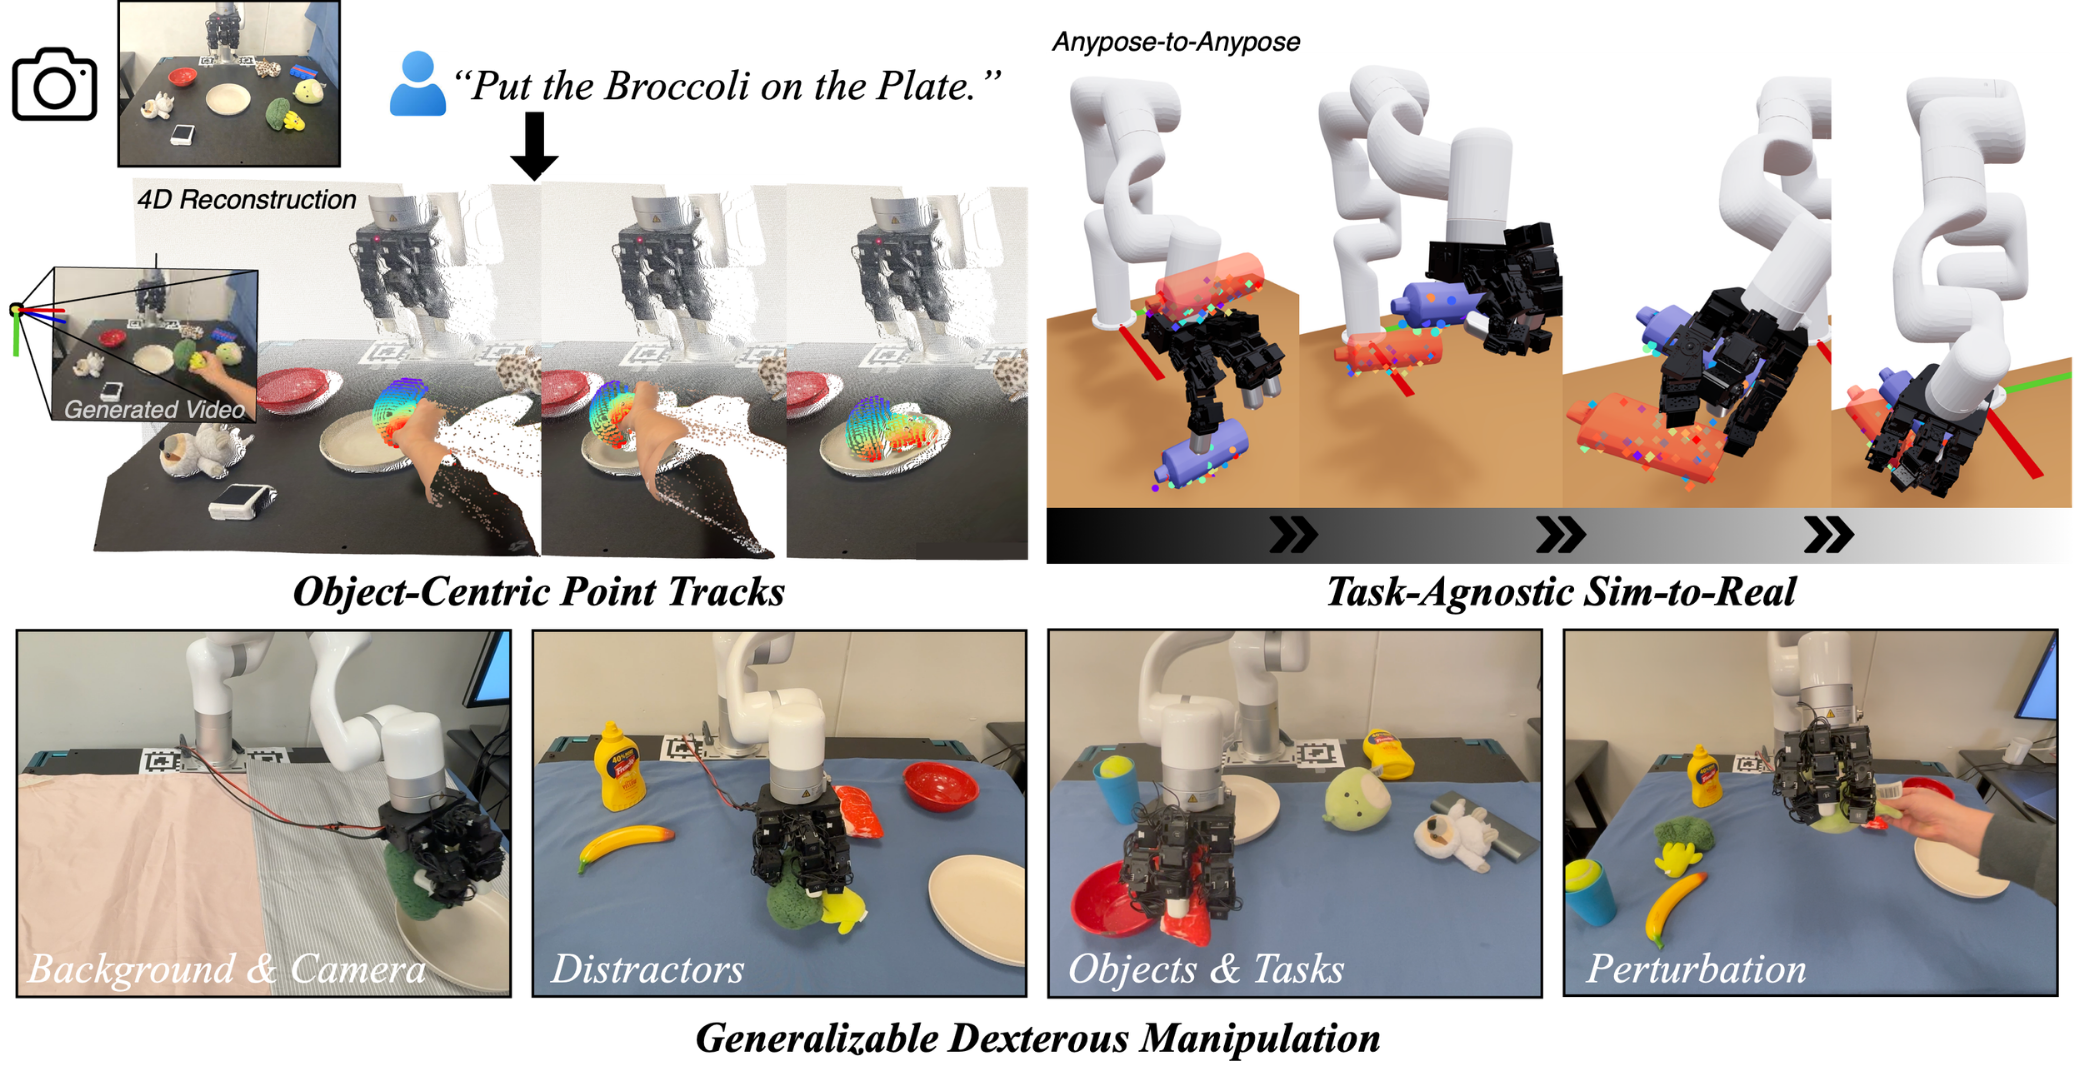
Yuxuan Kuang*, Jiashun Wang*‡, Yixuan Sun, Yufei Ye, Sungjae Park, Umar Iqbal, Katerina Fragkiadaki†, Shubham Tulsiani† Paper / Project / Code arXiv preprint, 2026. |
|
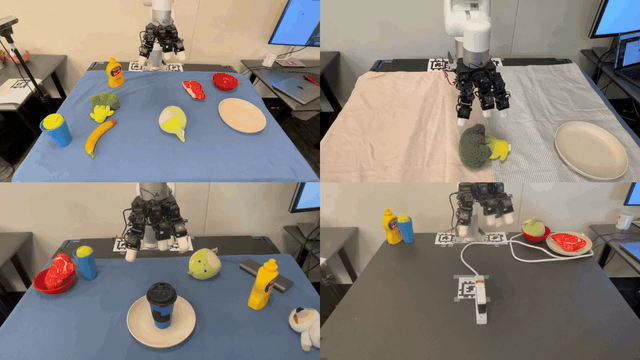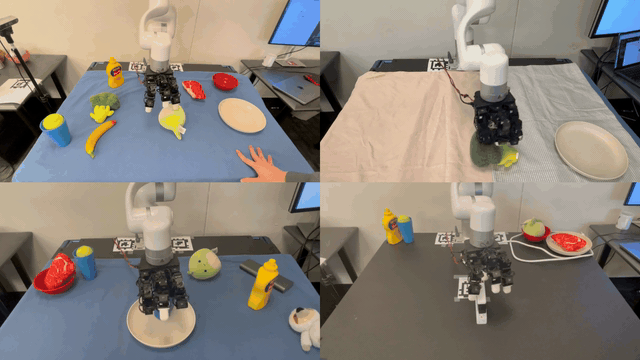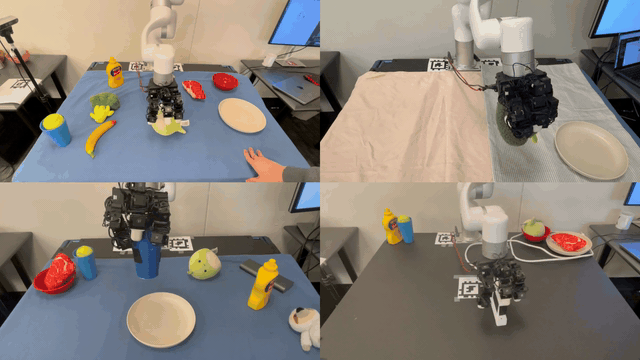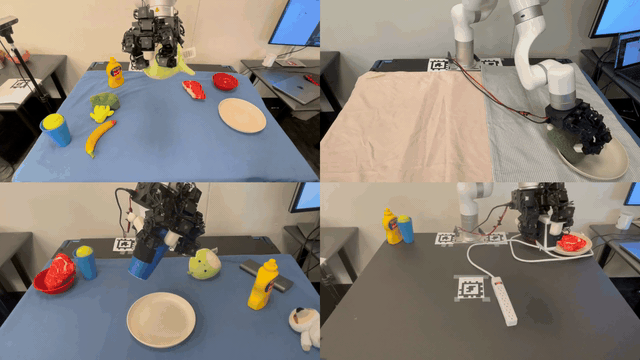
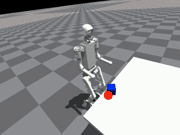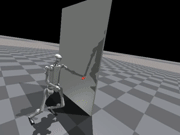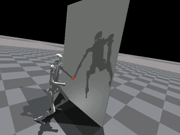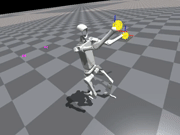
Yuxuan Kuang, Sungjae Park, Katerina Fragkiadaki†, Shubham Tulsiani† Paper / Project / Code Conference on Robot Learning (CoRL), 2026. |
|
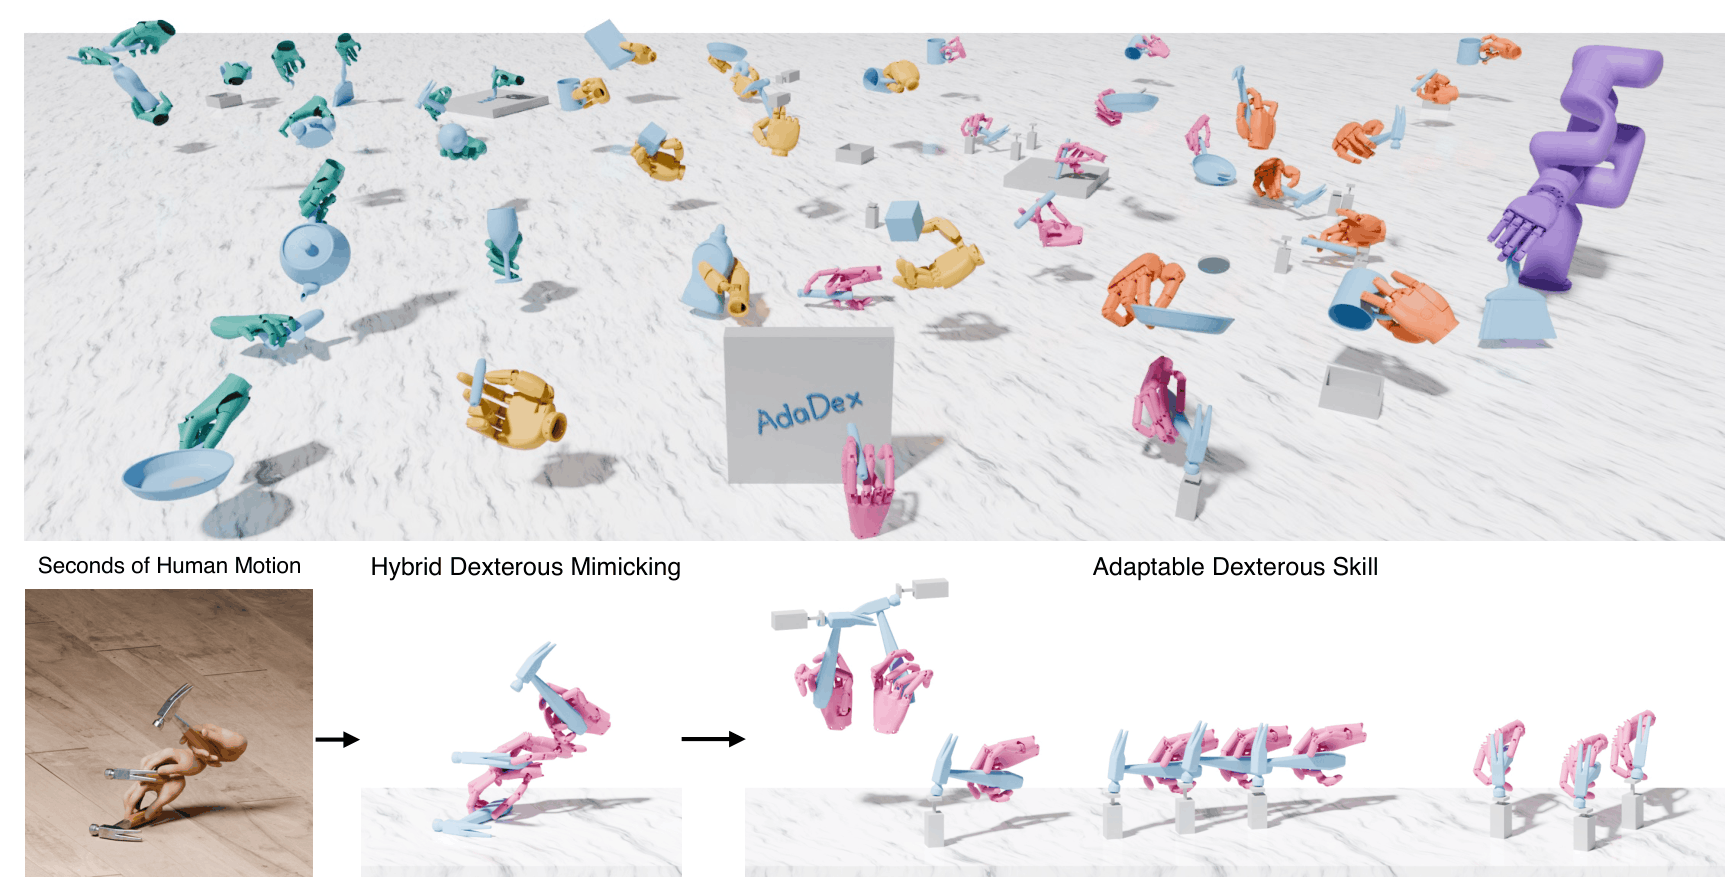
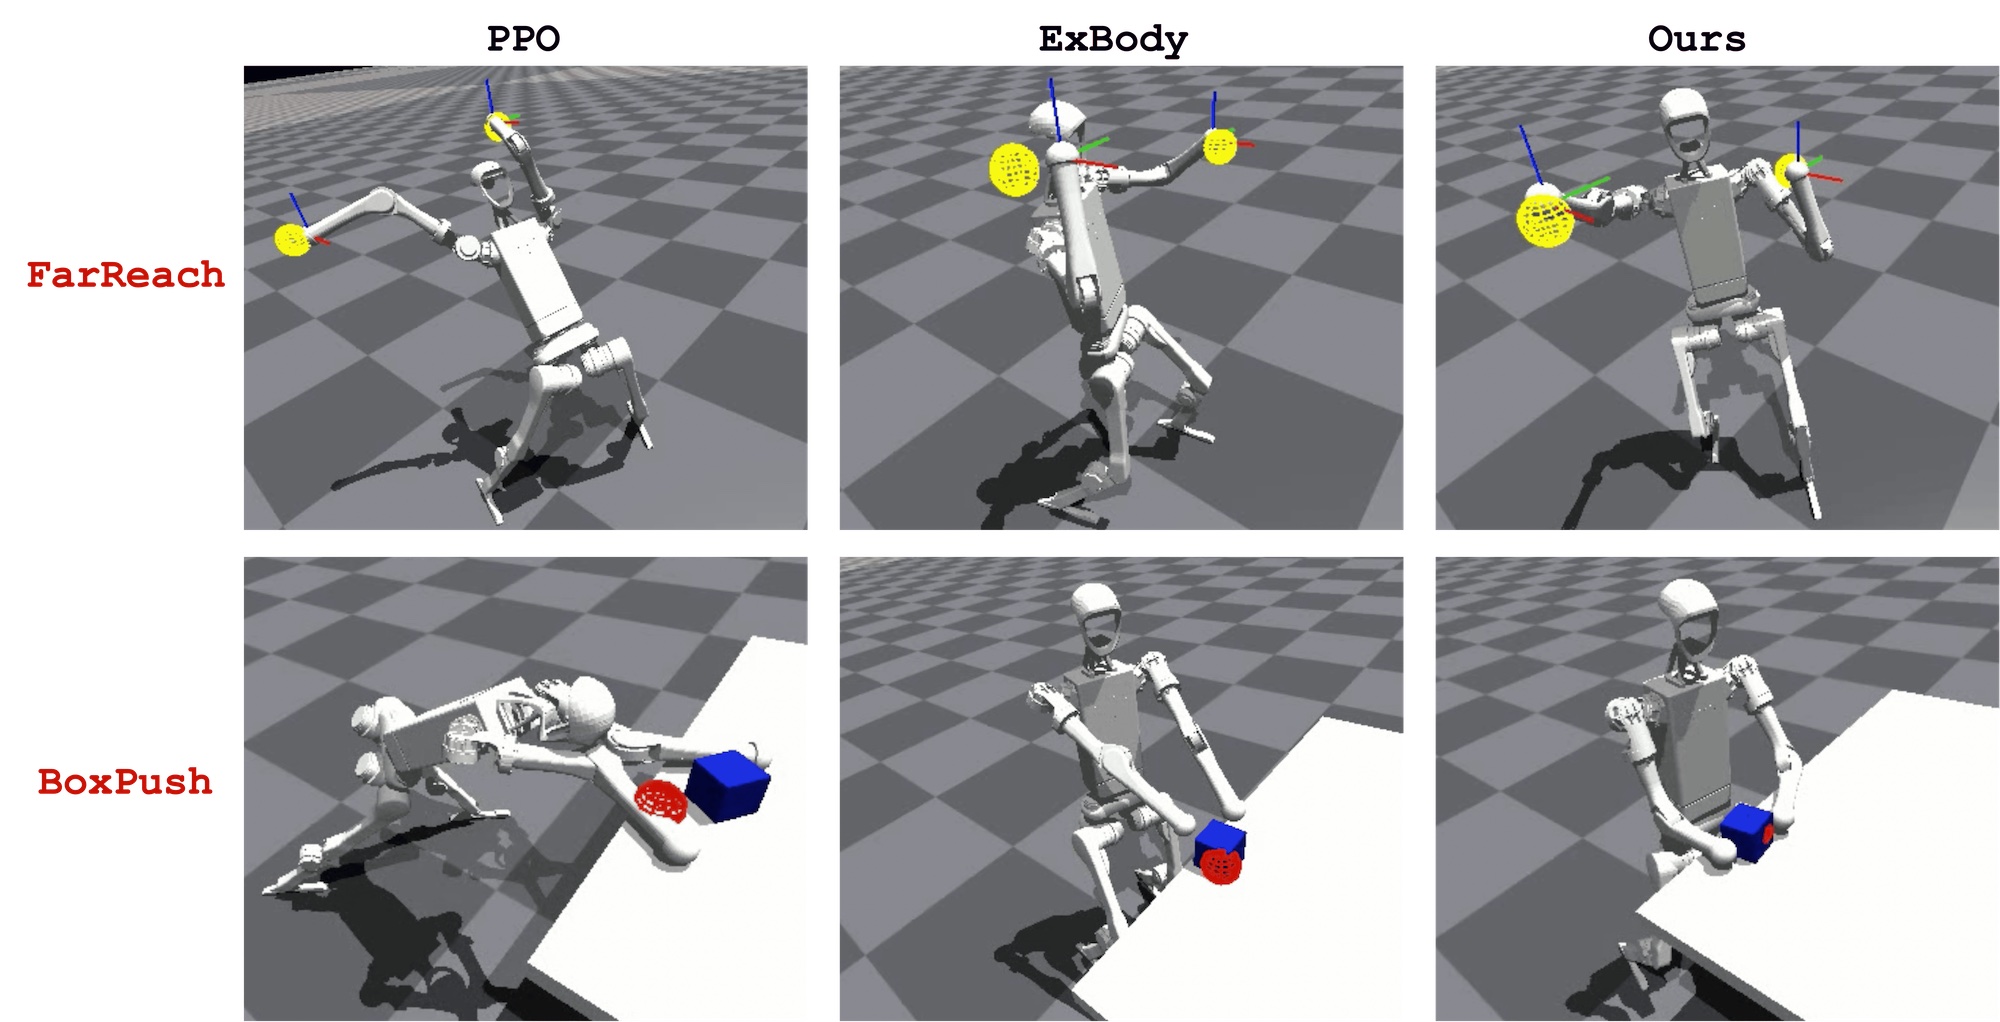
Yuxuan Kuang*, Haoran Geng*, Amine Elhafsi, Tan-Dzung Do, Pieter Abbeel, Jitendra Malik, Marco Pavone, Yue Wang Paper / Project / Code arXiv preprint, 2025. |
|
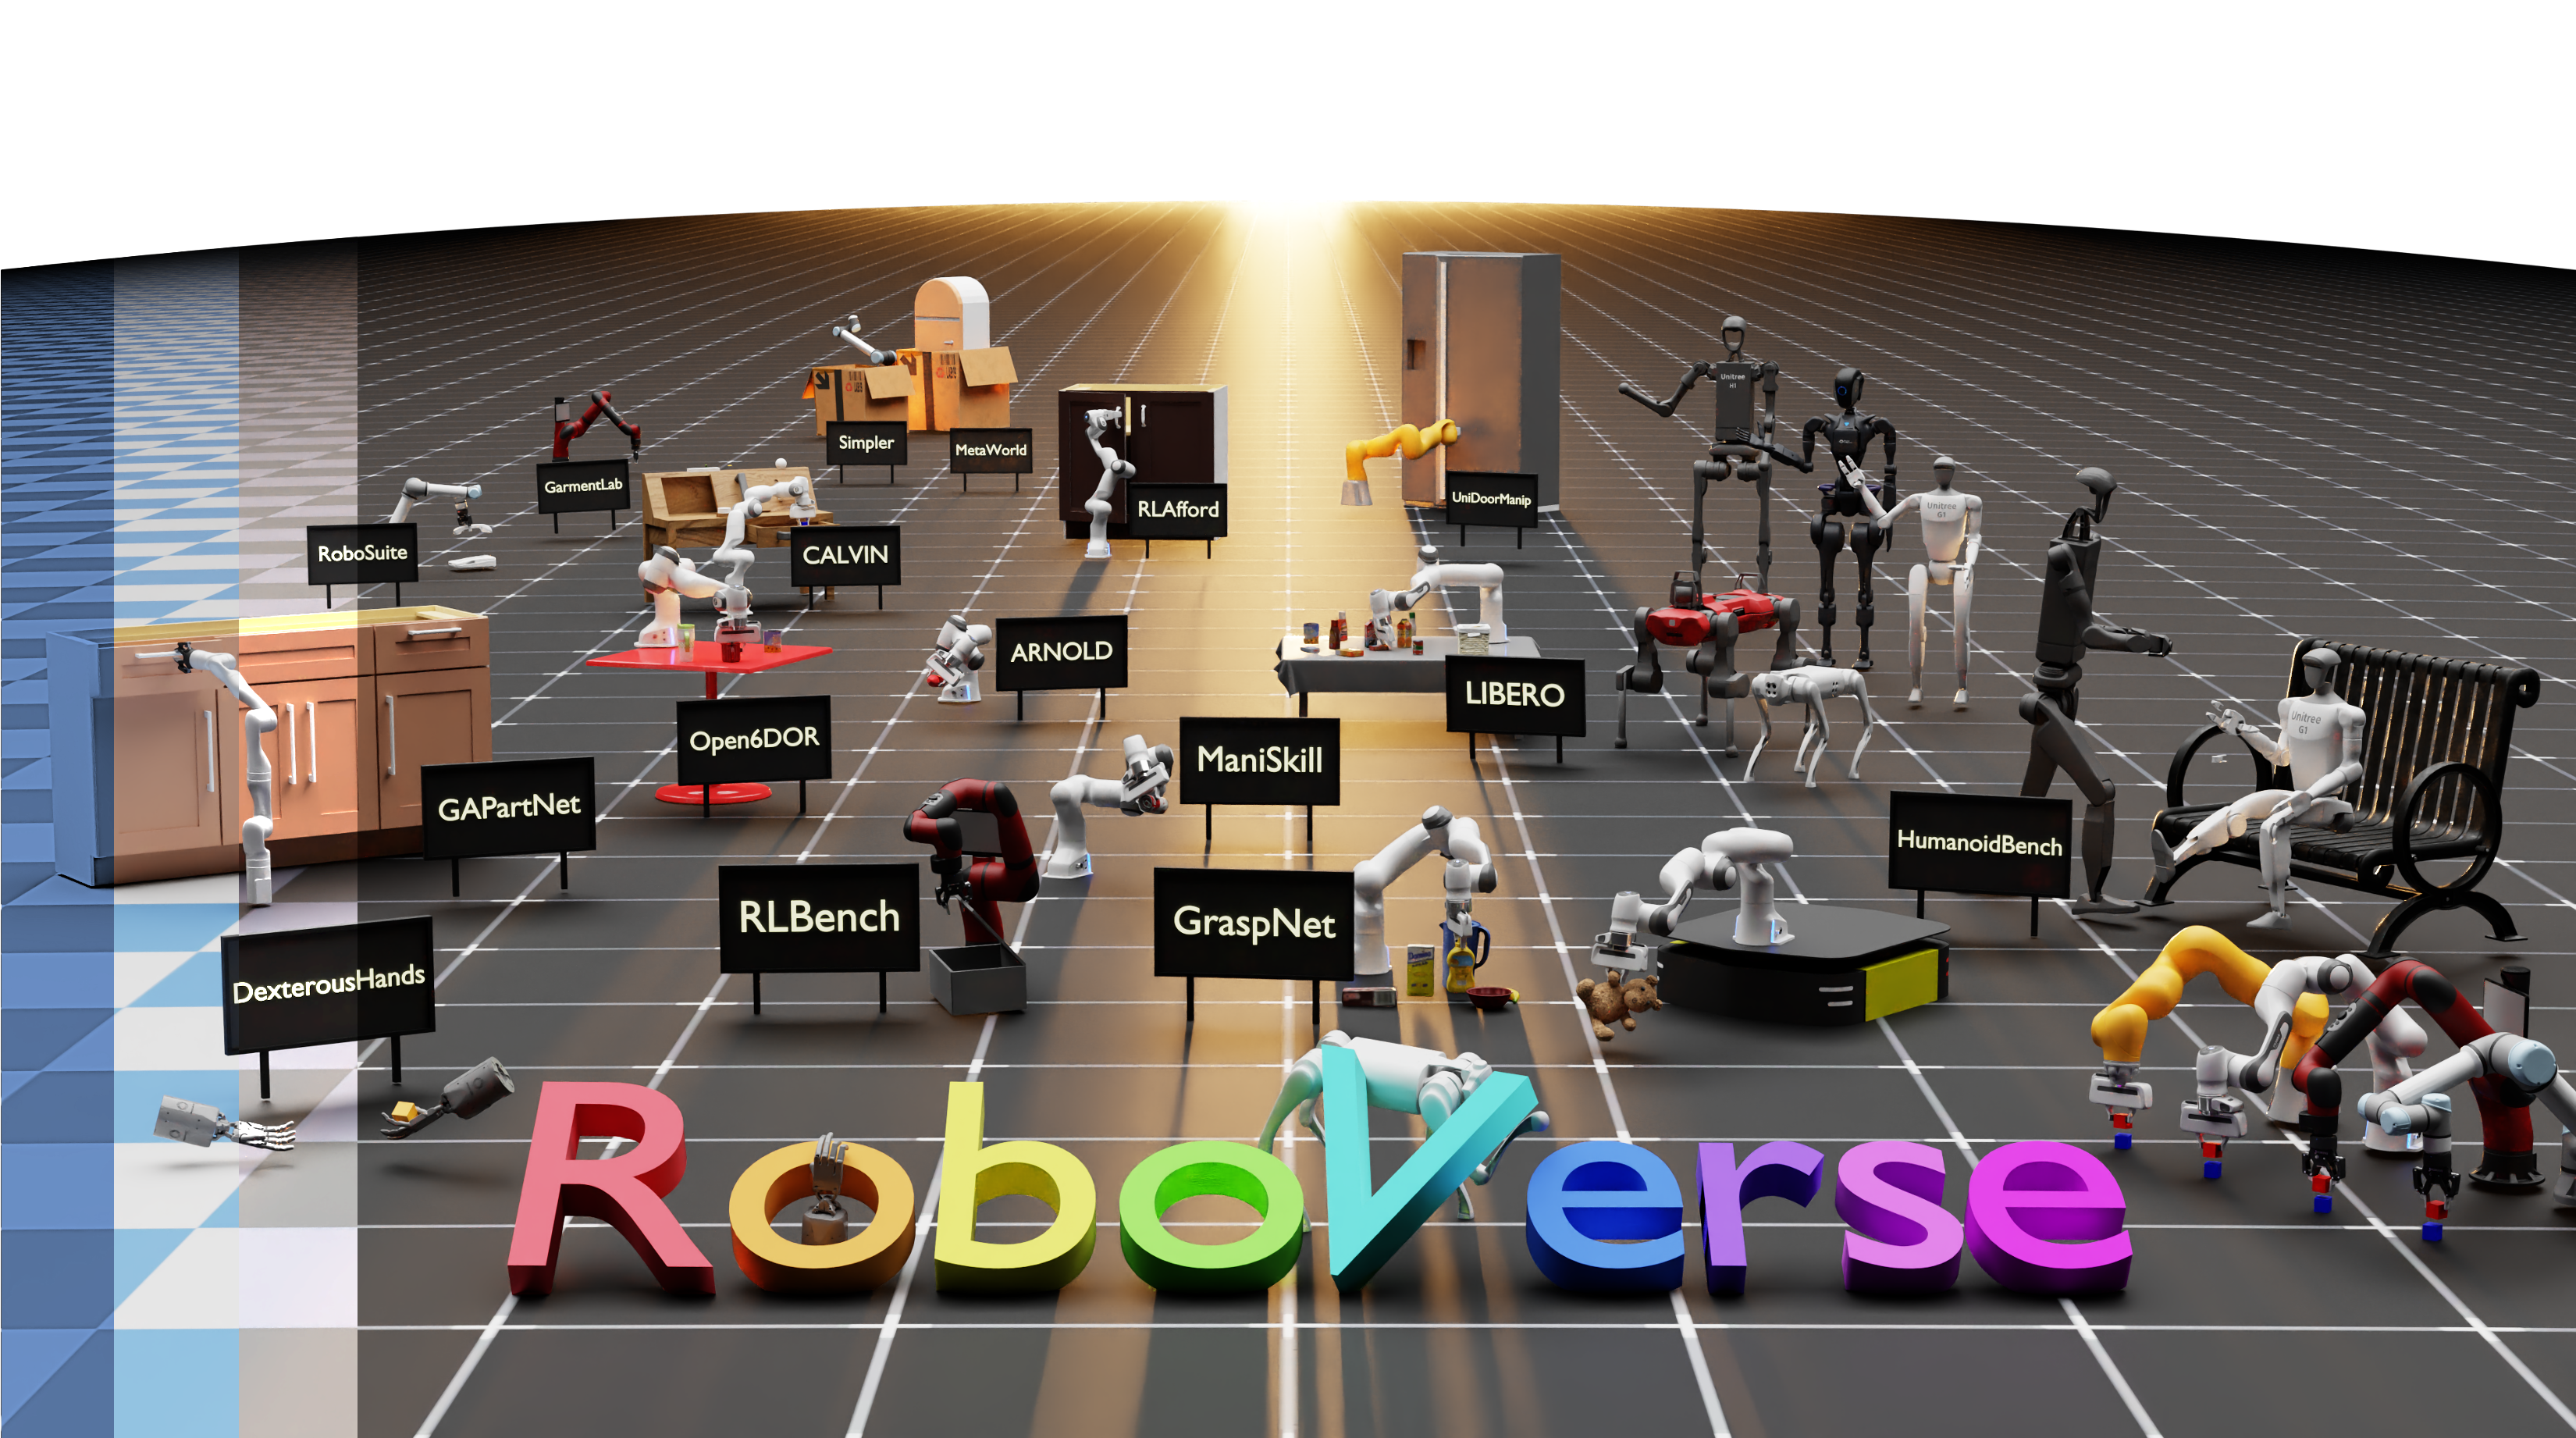
RoboVerse Team Paper / Project / Code Robotics: Science and Systems (RSS), 2025. (Oral Presentation) |

|
Weiheng Liu*, Yuxuan Wan*, Jilong Wang, Yuxuan Kuang, Wenbo Cui, Xuesong Shi, Haoran Li, Dongbin Zhao, Zhizheng Zhang†, He Wang† Paper / Project / Code Conference on Robot Learning (CoRL), 2025. (Oral Presentation) |

|
Rongtao Xu*, Jian Zhang*, Minghao Guo*, Youpeng Wen*, Haoting Yang, Min Lin, Jianzheng Huang, Zhe Li, Kaidong Zhang, Liqiong Wang, Yuxuan Kuang, Meng Cao, Feng Zheng†, Xiaodan Liang† Paper / Project / Code International Conference on Computer Vision (ICCV), 2025. |
|
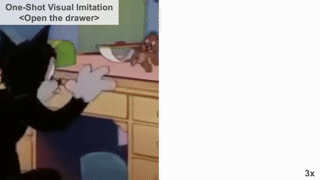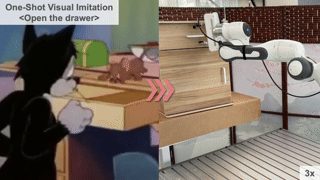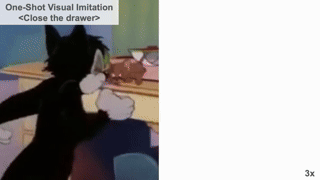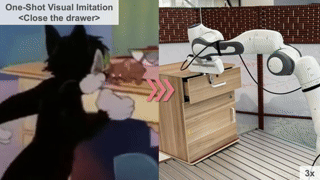
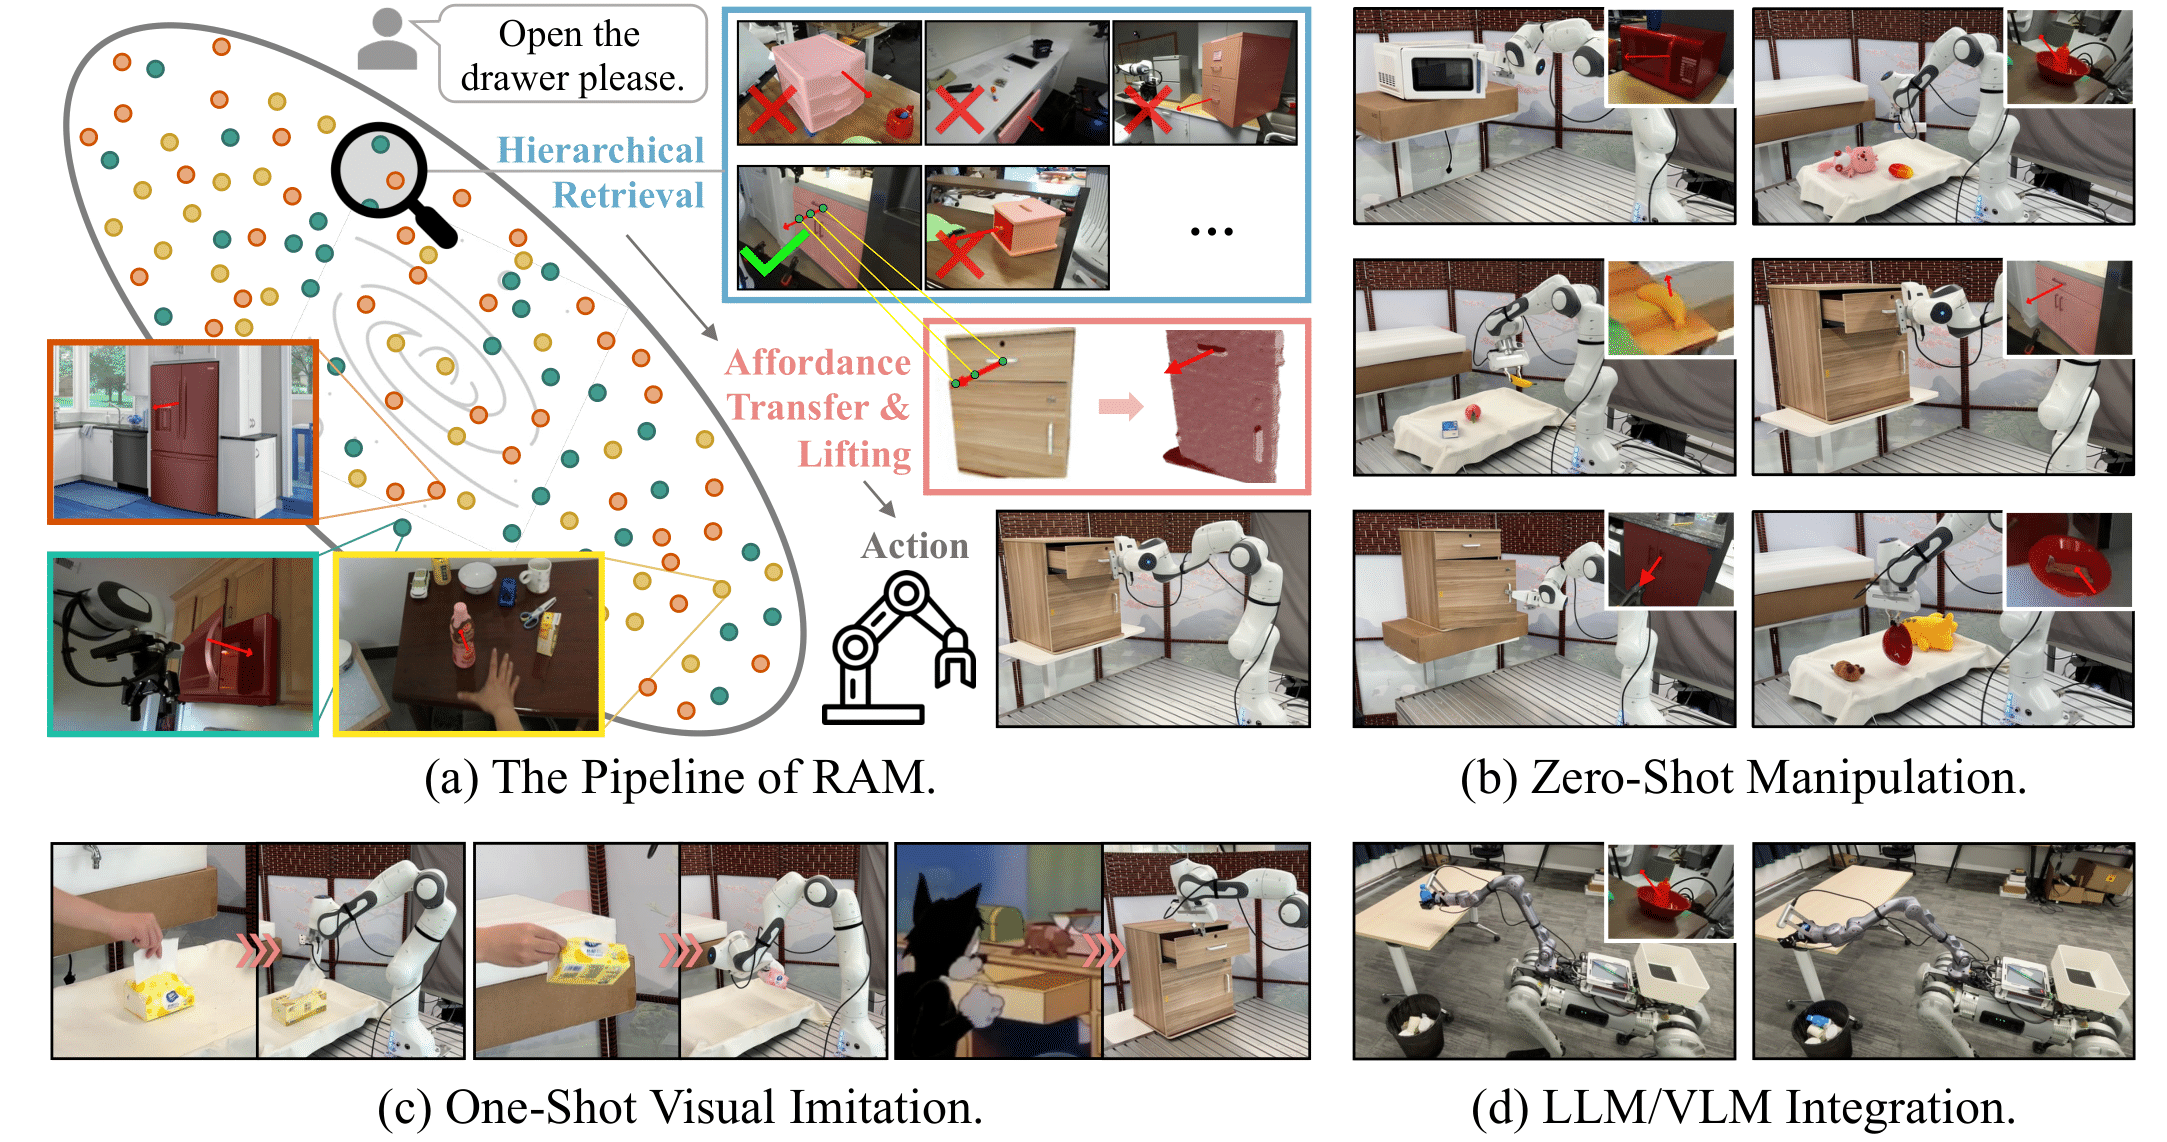
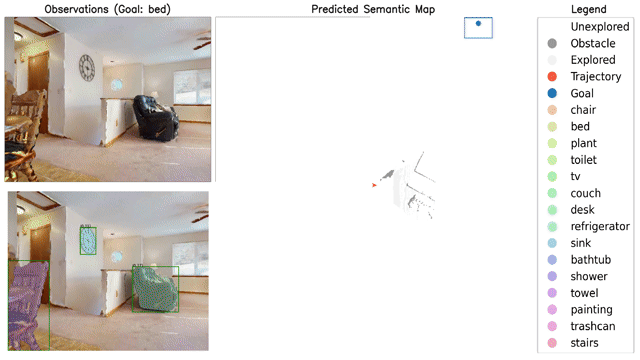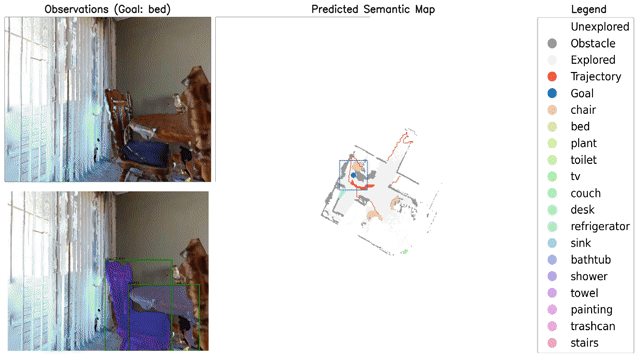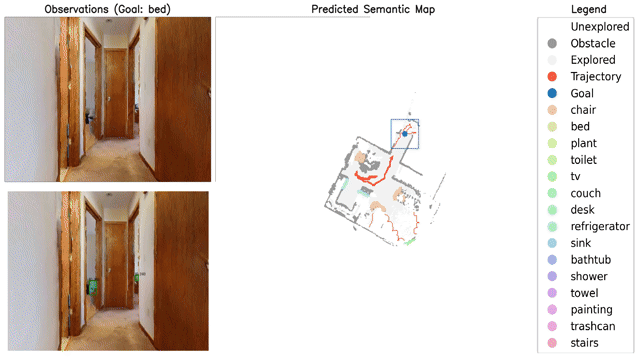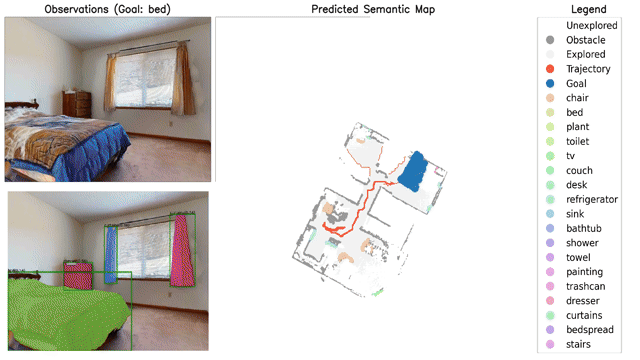
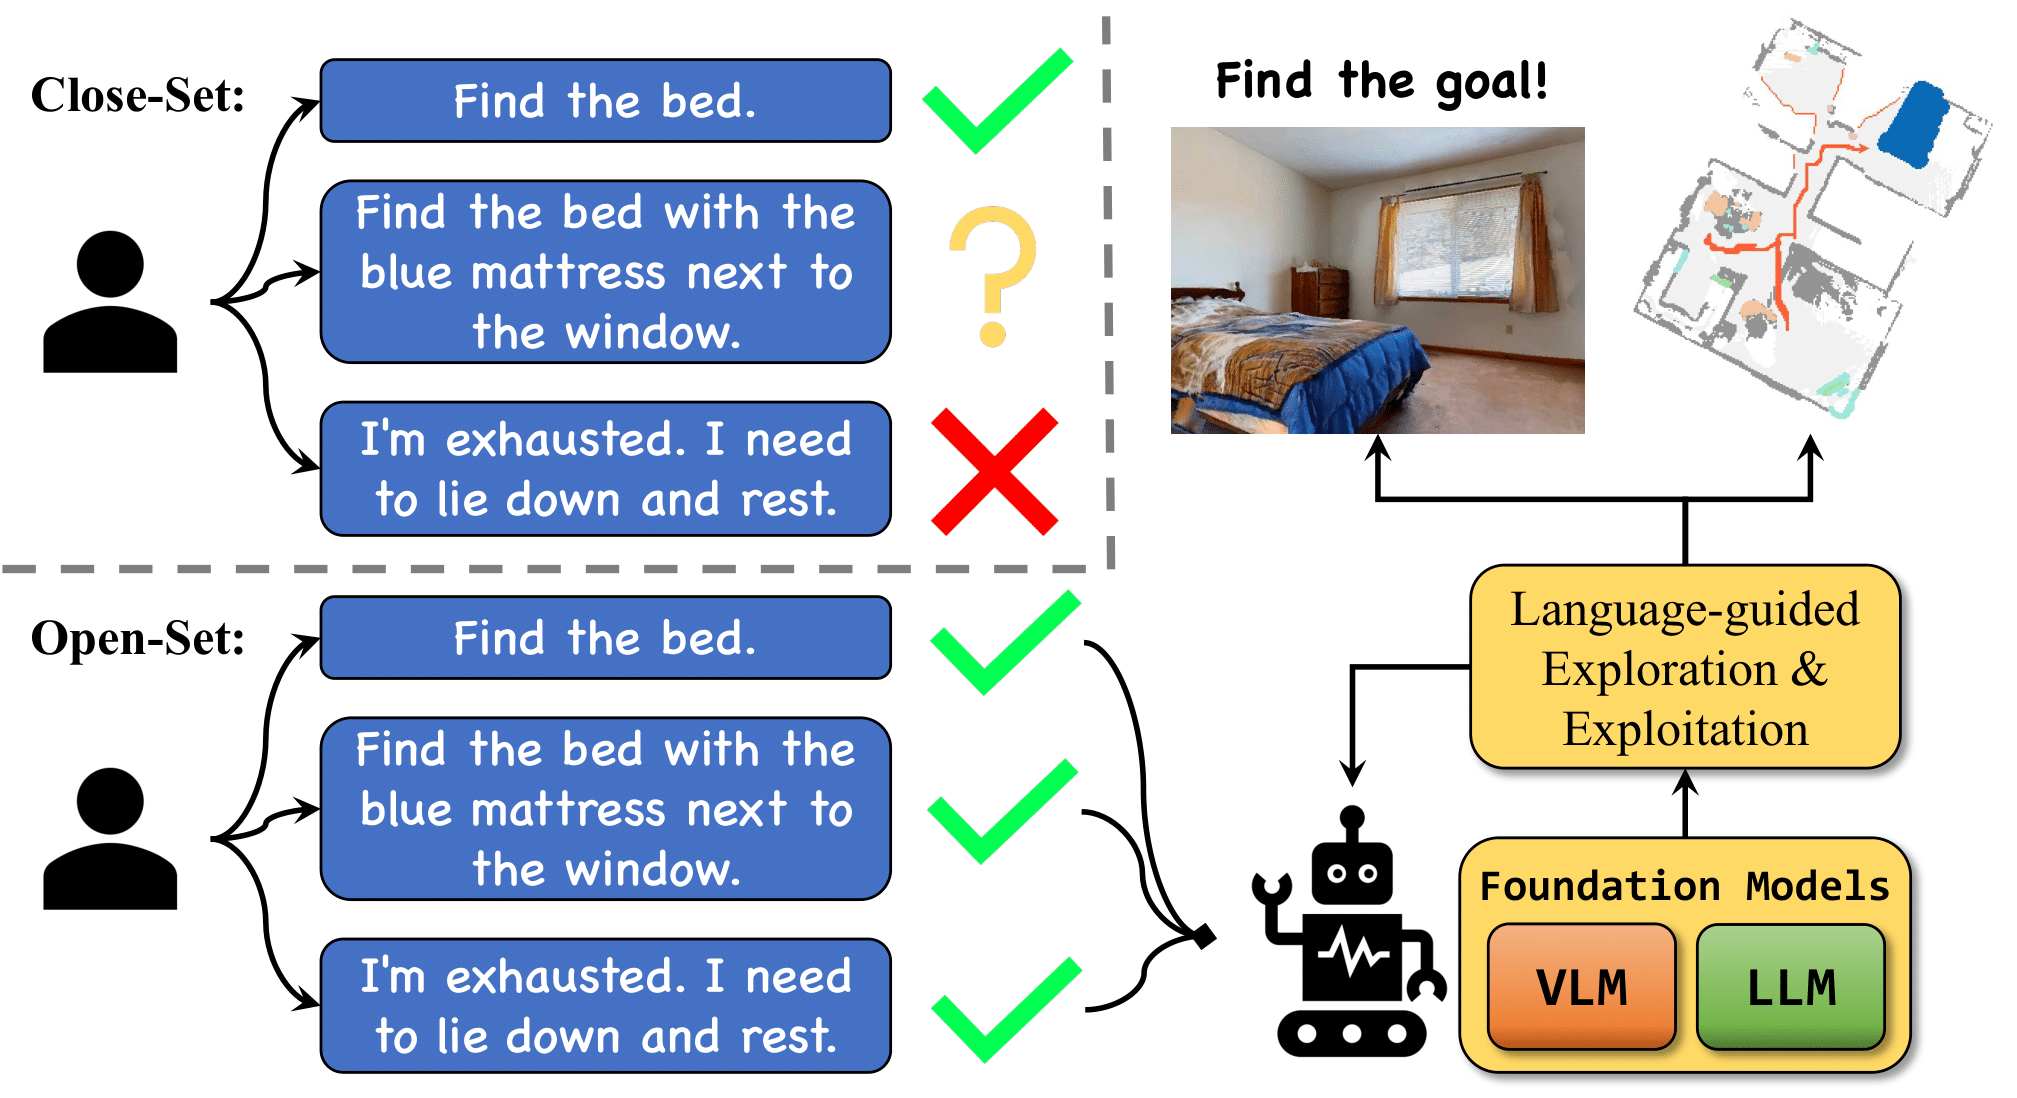
Yuxuan Kuang*, Junjie Ye*, Haoran Geng*, Jiageng Mao, Congyue Deng, Leonidas Guibas, He Wang, Yue Wang Paper / Project / Code Conference on Robot Learning (CoRL), 2024. (Oral Presentation, 4.5% acceptance rate) |
|
Yuxuan Kuang, Hai Lin, Meng Jiang Paper / Project / Code Findings of Annual Conference of the North American Chapter of the Association for Computational Linguistics (NAACL), 2024. |
|
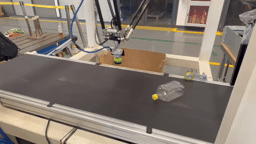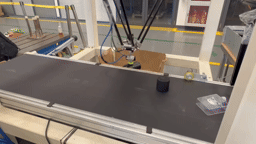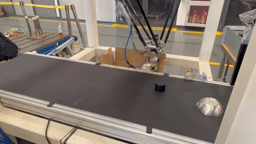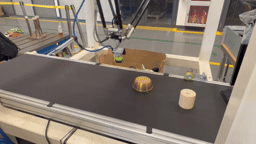
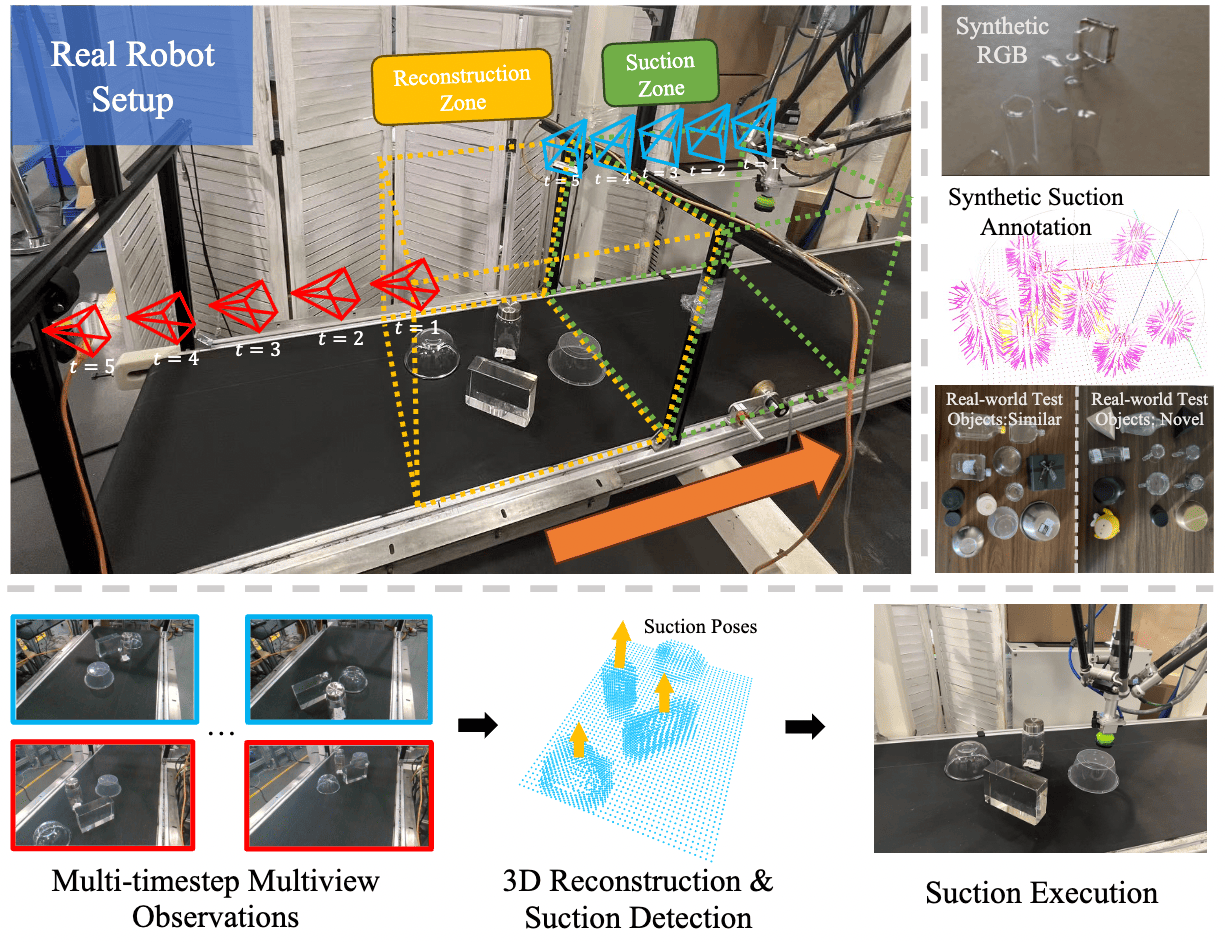
Yuxuan Kuang*, Qin Han*, Danshi Li, Qiyu Dai, Lian Ding, Dong Sun, Hanlin Zhao, He Wang† Paper / Project / Code International Conference on Robotics and Automation (ICRA), 2024. (Oral Presentation) |
|
|
|
|
|
|
|
|
|
Last updated in October 2026.
|